KUKA KR 300 R2700-2 C-F Cast Ceiling Mounted 6-Axis Heavy duty Industrial Robot
The official English original assembly manual for the body assembly, safety, technical parameters, transportation, debugging, maintenance, repair, and disposal of the cast ceiling mounted 6-axis heavy-duty industrial robot KR 300 R2700-2 C-F, compatible with KR C4/KR C5 controllers; The suffix C=Ceiling installation, F=Foundry casting environment version, with dust and coolant resistance, and casting specific positive pressure blowing function.
Product Description
Robot system composition: robotic arm body, controller, connecting cables, teaching pendant, software, tools and options.
The six major assemblies of the robotic arm body are: inline wrist, boom, connecting rod arm, hydraulic nitrogen balance system, rotating column, and base frame.
A1-A3 is equipped with mechanical terminal blocks for equipment protection only; Personnel protection relies on SafeRobot software or optional mechanical axis limit.
Balance system: Installed between the rotating column and the connecting rod arm, it belongs to Class I pressure equipment and consists of an accumulator, hydraulic cylinder, and explosion-proof plate to counteract the A2 axis gravity torque.
The wrist is a 3-axis straight row wrist, and the A6 motor is built into the upper arm; A4/A5 are driven by connecting the drive shaft.
All motor cables and signal cables use quick plug connectors, and the base is integrated with an RDC box.
Expected use and prohibition of misuse
Allow: tools for handling and handling workpieces, casting conditions; Environmental conditions and maintenance cycles must be followed.
Prohibited: climbing, carrying people and animals, outdoors, explosion-proof areas, radioactive environments, underground mining; Unauthorized use results in loss of warranty.
Robots belong to partially completed machinery and must be integrated into a complete set of CE compliant equipment before they can be put into operation.
Available options: brake release device, A1 hollow shaft cover, cable package cover, 4 blowing options A/B/C/D, mechanical shaft limit, energy supply pipeline package, etc.
Safety Regulations
This chapter focuses on the mechanical arm body; When paired with KUKA controllers, it is also necessary to read the controller safety chapter.
Disclaimer and EC Machinery Directive: Robots provide an ‘Integration Declaration’; The system integrator is responsible for the risk assessment of the entire system, issuing EC compliance statements, and affixing CE markings. It is prohibited to modify robots without authorization from KUKA. Any damage caused by third-party accessories shall be borne by the user; Even if all safety instructions are followed, it is impossible to completely eliminate personal injury and equipment damage.
personnel qualification
User: Implement labor safety, personnel supervision, and regular training;
Integrator: responsible for installing wiring, risk assessment, safety protection, and compiling system operation manuals;
Operator/maintenance personnel: Read all manuals thoroughly and pass professional training.
Area definition: Hazardous area=robot workspace+robotic arm+external axis stopping distance, must be physically protected; If there is no physical protection, the EN ISO 10218 collaborative robot standard shall be implemented.
Protective equipment: mechanical terminal block, optional A1-A3 mechanical shaft limit, release device, hazard warning nameplate; The nameplate is prohibited from being painted or removed.
Safety measures for various working conditions
General: If the controller is powered off, the robotic arm will still fall due to brake failure. It is strictly prohibited for personnel to stand under the arm; High temperature operation of the motor; Personnel wearing active implantable devices such as pacemakers must be at least 300mm away from the motor/brake; emergency stop failure occurs when the teaching pendant is disconnected; After modifying the robot, all safety functions must be fully tested; Immediately cut off power, lock and tag out the fault.
Transportation: The designated transportation posture must be maintained to avoid impact and vibration.
Start debugging: Change the default password of the controller; The robotic arm can only be matched with the corresponding model controller; Prevent condensation; Check for invisible collision damage before starting up; Complete testing of the safety circuit.
Manual mode: New/modified programs must undergo T1 (≤ 250 mm/s) testing; T2 high-speed mode is only used for testing, and the operator must be outside the danger zone.
Automatic mode: All safety devices are intact, and the danger zone is unmanned or meets the cooperation standards.
Maintenance and repair: power off and lock; Wait for several minutes for high-voltage components to discharge after power failure; The balance system operation must be mechanically locked with the arm body in advance; Refer to MSDS Chemical Safety Data Sheet for handling oil.
Discontinue storage disposal: comply with local laws and regulations.
Technical Data
Basic parameters of the ontology
Project KR 300 R2700-2 C-F
6 axes fully controlled
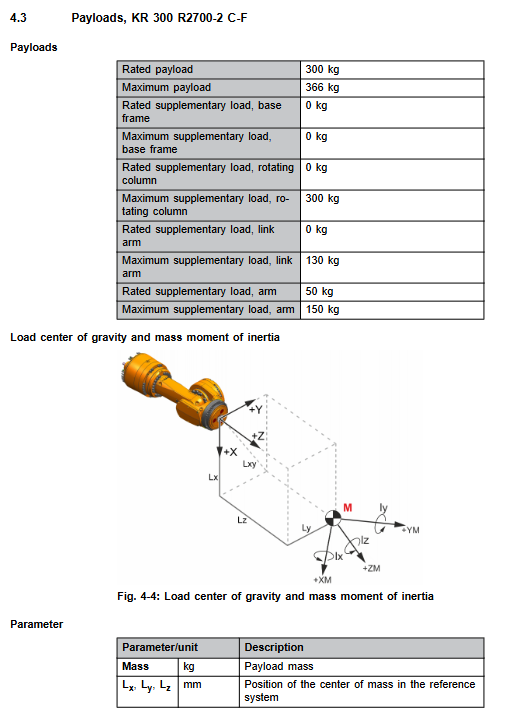
Rated load of 300 kg; maximum load of 366 kg
Maximum reach distance 2671mm
Repetitive positioning accuracy ISO9283 ± 0.05 mm
The self weight of the body is about 1105 kg
Protection level: IP65 for the main body; Wrist IP67
Noise<75 dB (A)
The installation method is only for ceiling installation, with a tilt angle of ± 0 °
Controller compatible with KR C4/KR C5 M6/M7
Casting plate special internal 0.3 bar positive pressure blowing, compressed air ISO8573-1, wrist short-term high temperature resistance of 180 ℃
Operating at an ambient temperature of 0-55 ℃; Storage -40~60 ℃
Axis motion parameters
Motion range: A1 ± 185 °; A2‑140°~‑14°; A3‑120°~+168°; A4/A6 ±350°; A5 ±122.5°
Maximum shaft speed under rated load: A1 105 °/s; A2 101 °/s; A3 107 °/s; A4 140 °/s; A5 113 °/s; A6 180 °/s
Load capacity: Provide wrist flange ZH300 parameters (flange diameter 160mm, M10-10.9 bolts); Load center of gravity, moment of inertia, load curve diagram; Distinguish between normal operation and emergency stop conditions, where the flange is subjected to axial force, radial force, overturning moment, and torsional moment; Additional loads are allowed to be added to the boom, connecting rod arm, and rotating column.
Base load (ceiling working condition): Provide vertical force, horizontal force, overturning moment, A1 torque, divided into normal working condition and emergency stop maximum value; The steel structure base must be structurally checked according to the maximum value, otherwise there is a risk of the robot falling.
Cable parameters: distinguish between KR C4 and KR C5 cable definitions; The standard length of motor cables and data cables is 7-50 meters, with a maximum total length of 50 meters, and a maximum extension allowed once; It is necessary to independently protect the grounding; Provide the pin diagram for the A1 base interface.
Stop distance and stop time: distinguish between STOP0 (cutting off the brake) and STOP1 safe stop; Provide stop angle and stop time charts for A1-A3 under different stretching ratios, loads, and program magnification POV; The brake has wear and tear, it is recommended to review the stopping distance annually.
Nameplate labels, REACH regulation information, and two-dimensional drawings of work envelopes.
Planning and Design
Accelerated wear conditions: long-term temperature limit operation, abrasive dust environment, continuous approach to performance limit, single axis high duty cycle, short cycle reciprocating motion, external process forces; If the above working conditions occur, it is necessary to consult KUKA to shorten the maintenance cycle.
Rack mounted installation: The robot ceiling must use rack mounted components, including 8 M24 bolts and positioning pins; Strict requirements are given for the flatness, roughness, and stiffness of the installation base.
Cable planning: The minimum static bending radius for motor cables is 150 mm, and for signal cables it is 60 mm. Motor cables and data cables are laid separately in metal cable trays to achieve EMC electromagnetic compatibility; Double grounding; Cable layout eliminates the risk of tripping.
Transportation
Forced transportation posture (maintained throughout the entire transportation process): A1=0 °, A2=-137 °, A3=160 °, A4=0 °, A5=-105 °, A6=0 °. It is not allowed to change the posture without fixing the base to prevent overturning.
Shipping Method
Forklift: The base comes with a fork groove, and the minimum rated load of the forklift is 2 tons;
Crane: KUKA specialized lifting equipment is selected, with lifting points distributed on rotating columns and base fork slots; The lifting chain must be adjusted to ensure that the robot is suspended vertically.
Transportation prohibits non-standard lifting points; Avoid impact and vibration throughout the transportation process; Transport completed and lifting equipment removed. Provide the overall dimensions and center of gravity position for the transportation of the entire machine.
Startup Debugging and Restarting
This robot adopts a rack mounted ceiling installation, and the key process points are:
Prerequisite: The robot is in a transport position, the steel structure base is completed, and the lifting equipment is in place.
Installation Steps
Clean the interface between the base and the robot, and install the positioning pin;
The crane vertically lifts the robot into position to prevent damage to the positioning pin from collision;
Tighten 8 M24 bolts diagonally in multiple stages to the specified torque;
Connect dual protection grounding (torque 23 Nm);
Connect motor cables XD30/X30 and data cables XF31/X31 for KR-C4 and KR-C5 respectively; Confirm that the connector lock is in place;
Complete controller configuration and set the robot ceiling installation posture;
Install tools and complete the overall power on debugging according to the controller manual; There is a risk of air accumulation after balancing the system storage, and the A2 axis swings slightly to release the air from the pressure relief valve.
Provide complete wiring diagrams for motor cables, data cables, and grounding cables of KR-C4 and KR-C5.
Maintenance
Only maintenance projects recorded in this document can be executed; The remaining repairs will be handed over to KUKA training personnel; The maintenance cycle is shortened when the oil temperature is above 60 ℃; Emergency stop and lock before maintenance.
Maintenance cycle summary table
Periodic homework content consumables
After being put into operation, only one 100 hour recheck of the base bolt torque is required
Add LGEP2 grease to two bearings of the balance system at 2500 hours or at the latest 1 year; Check the balance system nitrogen pressure LGEP 2 lubricating grease, Hyspin ZZ46 hydraulic oil
10000 h or at the latest 5 years, all gearboxes of A1-A6 should be replaced with Optigear Synt. ALR 150 gear oil; Oil filling amount for each axis A1=8.30 L; A2=2.10 L; A3=1.40 L; A4=2.10 L; A5/A6=1.90 L
Replace the entire balance system with the original balance cylinder assembly in 10 years
7 years or changes in working conditions, it is recommended that KUKA conduct on-site inspection of the entire machine.
Key maintenance process
General rules for gearbox oil change: The gearbox needs to be at operating temperature; Measure the actual amount of oil released during oil discharge; If the oil release rate is less than 70% of the rated value, the gearbox must be flushed; Rinse twice below 50%, and move the entire stroke during rinsing; Magnetic plug inspection for metal debris; Oil change completed T1 mode jog operation, check for leaks. The ceiling robot A1 has a special oil discharge and injection pipeline, which is operated from the base interface.
Balance system maintenance (high-risk pressure components)
Pressure detection: The minimum pressure in an environment at 20 ℃ is 244.8 bar. If it is lower than this value, the entire balance system must be replaced;
Replacing the balance system: To replace the balance cylinder of the suspended ceiling robot, the robot must first be disassembled and fixed to the ground; Use a sling to secure the connecting rod arm throughout the entire homework process; The complete process of pressure relief, disassembly, installation, and recharging. The weight of the balance system is about 40 kg, with high-pressure oil and gas inside. Unauthorized personnel are strictly prohibited from disassembling it.
Robot cleaning: Do not use high-pressure water guns or compressed air to blow the bearing seals; Use solvent-free water-soluble neutral cleaning agents; Power off operation to prevent liquid from entering the motor gearbox.
Maintenance
The manual provides detailed steps for replacing A1-A6 motors, straight row wrist assemblies, and connecting drive shafts.
General safety for motor replacement: power off, lock the main switch, wait for 5 minutes for high voltage discharge; Before disassembling the motor, the corresponding shaft must be locked with a sling/fixture to prevent the arm from falling; Dismantle the old motor, check that the involute spline is not damaged, and evenly apply Microlube GL261 grease; O-rings and seals must be inspected and replaced if damaged; Tighten the bolts diagonally in steps; After the motor installation is completed, the axis must undergo Mastering zero calibration and T1 mode trial operation.
Special difficulties:
Dismantling of A2/A3 motors requires fixing the connecting rod arm/boom with a sling to prevent the balance system from falling after unloading;
A6 motor: It is necessary to first remove the A4 and A5 motors, and then remove the entire straight row wrist before removing the A6 motor;
To replace the straight row wrist assembly and transmission shaft, it is necessary to sequentially remove the A4/A5 motors and disassemble the wrist.
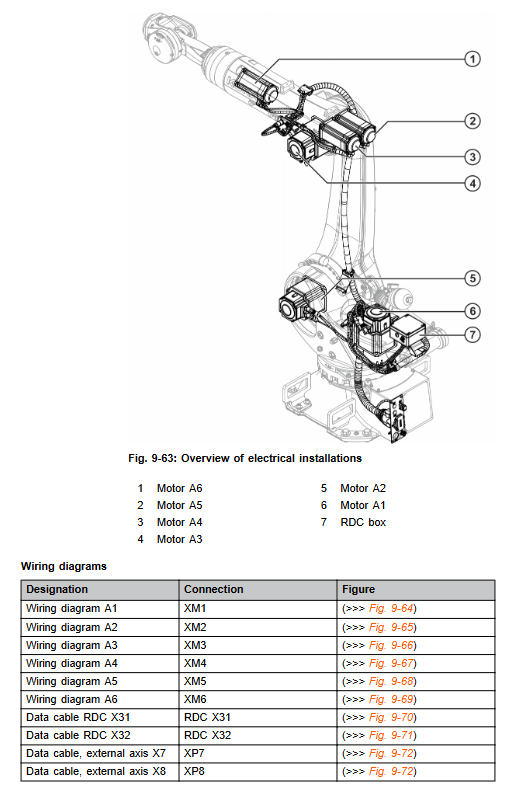
Overview of electrical wiring, definition of connectors; Repairs must use KUKA original spare parts; Verify all safety functions after repair.
Suspension, Storage, and Disposal
Shutdown disassembly: Move the robot to the transport position; Install lifting equipment; Disconnect all cables; Lift the crane off the robot body.
Storage: Maintain transportation posture, clean the robot, take rust prevention measures, and meet temperature and humidity storage conditions.
Scrap disposal: Lubricating oil, hydraulic oil, electronic components, and metal structures shall be classified and disposed of in accordance with local environmental regulations.
Options
Release device: manually move the robotic arm in power-off state; Operation steps and safety requirements.
A1 hollow shaft cover; Cable wrap cover.
Foundry Casting Edition 4 sets of blowing options A/B/C/D: Inject dry compressed air into the interior of the robot to maintain positive internal pressure and prevent dust and casting coolant from entering the interior.