KUKA KR 500 MT FORTEC Heavy duty Six Axis Industrial Robot
The product includes KR500 R2830 MT, KR500 R2830 MT-F, KR480 R3330 MT, KR480 R3330 MT-F; F represents the casting enhanced version, compatible with KR C4 and KR C5 controllers; Robots belong to semi-finished machinery, and the CE compliance and risk assessment of the entire machine are completed by the system integrator.
Product Description
Composition of a complete robot system
Robot arm body, controller, smartPAD teaching pendant, connecting cables, system software, optional accessories.
Structure of Robot Arm Body
6-axis series heavy-duty robot, casting+lightweight alloy, driven by AC servo motor; The A2 axis is equipped with a hydraulic pneumatic balance cylinder system, which offsets the gravity load of the connecting rod and belongs to pressure equipment. Main components: base frame, rotating column, connecting rod arm, forearm, Inline hollow wrist, RDC box, MFH multifunctional housing.
MT-F casting enhanced variant: wrist protection level IP67; Continuously introducing 0.1 bar of dry and clean compressed air into the body to establish internal overpressure and resist dust, coolant, and water mist; Special anti-corrosion coating on the surface. The regular MT version has an IP65 rating for the wrist.
Electrical: RDC parser, motor/signal cables; External connectors at the rear of the base.
Optional accessories: mechanical hard limit, mechanical shaft angle limit module, no drive release device (power off manual release brake mobile manipulator).
Designated use and prohibition of misuse
Designated use: for handling, tooling processing, heavy processing, etc., used within rated environmental parameters and must be integrated into complete equipment.
Misuse (loss of warranty): manned, outdoor, explosion-proof area, radioactive environment, personnel stepping on the body; Overloaded and overtraveled operation.
The main body is a semi-finished mechanical equipment and cannot be directly put into use. The integrator completes the overall risk assessment and CE.
Technical Data
Includes complete parameters for four major models: KR500 R2830 MT/MT-F and KR480 R3330 MT/MT-F.
Model Rated load Maximum load Maximum weight of the main body
KR500 R2830 MT 500 kg 611 kg 2826 mm ~2440 kg
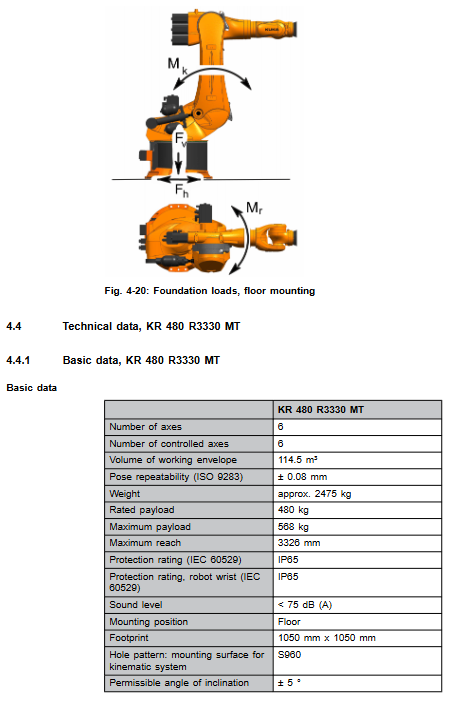
KR480 R3330 MT 480 kg 568 kg 3326 mm ~2475 kg
General Parameters
Repetitive positioning accuracy ISO9283: ± 0.08 mm; noise<75 dB (A).
Protection: MT body IP65; F-wrist IP67.
Environmental conditions: operating temperature of 10~55 ℃; Storage -25~60 ℃; Environmental level 3K3.
Flange standard ISO 9409-1-200-11-M12; 12 M12 to 12.9 bolts.
Cable: compatible with KR-C4/KR-C5; Motor cables, RDC data cables, 16mm ² equipotential grounding wires; The maximum length of the cable is 50 meters.
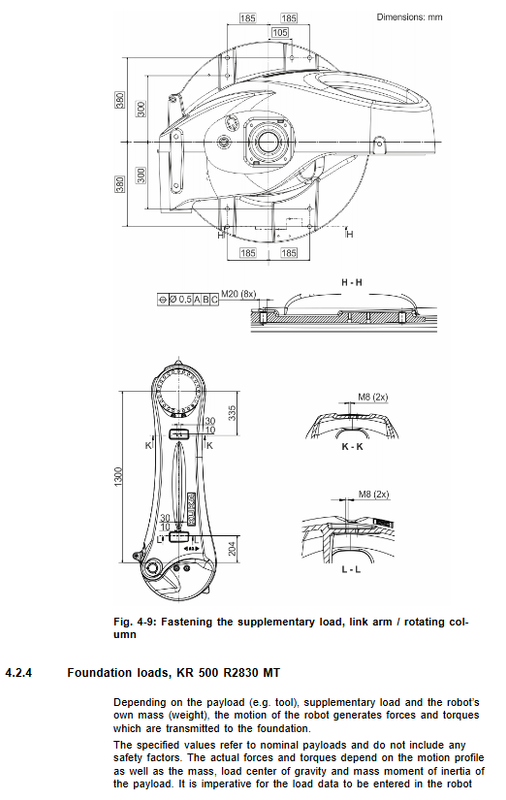
Load description: It is not enough to only consider the quality. The center of gravity Lxy/Lz and moment of inertia must be calculated using the KUKA Load tool, and the load parameters must be entered into the controller. Otherwise, the gear motor will be damaged due to overload. Allow the installation of additional loads such as pipeline packages on columns, connecting rods, and small arms, and provide the maximum allowable additional load for each part.
Flange stress: distinguish between normal operating conditions and emergency stop peak conditions; The value does not include a safety factor, and additional safety factors must be added to the design of tools and fixtures.
Base foundation load: outputting vertical force, horizontal force, overturning moment, A1 turning torque, providing normal and peak values; The value does not include a safety factor, and the civil engineering design must increase the safety factor.
Stopping distance and time: According to DIN-EN-ISO 10218-1, distinguish between Stop0 (cutting off power) and Stop1 paths to maintain stopping; Provide A1-A3 axis shutdown angle/time charts for different POV speed ratios and load ratios; The stopping distance of multi axis compound motion will increase; It is recommended to check the stopping distance of the brake every year.
Check the KUKA Xpert system for nameplate labels and REACH SVHC substances of high concern.
Project Planning and Design
Base selection: 175mm base S960, 200mm base S960, and complete machine rack frame installation. Concrete grade C20/25; Insulation layer and leveling mortar interlayer are prohibited between the bottom plate and concrete; It is necessary to ensure anti overturning and prevent the robot from tipping over.
Cable planning: differentiate the specifications of KR-C4 and KR-C5 motor cables and data cables; Requirements for equipotential grounding.
Casting version: Compressed air parameter requirements, ISO8573‑1 (7:4:4), Pressure 0.01 MPa (0.1 bar).
Transportation
Standard transportation posture must be specified in the document; Provide lifting points and hoist numbers; Only KUKA approved lifting equipment can be used; Provide a drawing of the forklift fork slot position.
Transportation prohibits impact and falling; Lifting operations must be prevented from tipping over. In special circumstances, the A2 buffer block can be removed and a special transport posture can be used.
Startup and Restarting
Base installation process: Installation of 175mm base, 200mm base, and machine frame rack; Chemical anchor bolt construction and leveling, with a maximum allowable inclination of 3 °; Limitations on the use of leveling mortar; Tighten the bolts diagonally in steps; After 100 hours of operation, all fixing bolts must be tightened again.
Robot body landing installation: hoisting in place, positioning pin positioning; Apply torque to M24 bolts diagonally in steps.
Cable connection: Describe the pin definitions of the connectors for the KR C4 and KR C5 controller motor cables, data cables, and equipotential grounding cables; Cable laying should avoid tripping risks.
F-version put into operation: connect compressed air and adjust the pressure to 0.1 bar.
Operation checklist: Confirm no condensation; The body has no collision damage; Locking of connectors; Equipotential conduction test; All safety equipment function tests.
Balance cylinder exhaust: After long-term storage, the balance cylinder will accumulate air cushion, and exhaust operation is required before operation to prevent the protective cover from popping out and injuring people.
Chapter 8 Maintenance (Before maintenance, power must be cut off, locked and tagged, ESD protection)
Important: If the oil temperature exceeds 60 ℃, the maintenance cycle needs to be shortened. The maintenance table defines various job cycles (5000h, 10000h, 15000h, 20000h).
Lubrication operation
A4/A5 axis O-ring with lubricating grease Microlube GL261;
Balance cylinder bearing lubrication LGEV2/5; Check the axial clearance of the A4-A6 drive shaft universal joint (if it is greater than 0.8mm, it must be replaced);
Cable package lubrication Optitemp RB2.
Gearbox oil change: A1-A6 and A1/A2/A3 input stage gearboxes, oil Optigear Synt. ALR 150; Every 20000 hours or 5 years; Detailed steps for draining and injecting oil; Record the amount of oil released as a reference for refilling oil; If the oil discharge is less than 70%, the gearbox needs to be flushed.
Balance cylinder system maintenance: Check pressure and leaks every 5000 hours; Complete disassembly and assembly steps for the balance cylinder of the ground and ceiling versions; Before disassembling and assembling the balance cylinder, the connecting arm must be mechanically locked and a lifting device must be used to support the components; The balance cylinder is a pressure component, and there is a risk of compression injury during operation. The replacement of the balance cylinder for ceiling models requires the robot to be removed from the ceiling and placed on the ground for operation.
Body cleaning: power off; Do not use high-pressure water guns or compressed air to blow the bearing seal; Neutral soft cloth cleaning; Replace the damaged nameplate in a timely manner.
All maintenance is completed, and safety function retesting must be performed.
Maintenance
Repairs beyond the scope of this manual must contact KUKA certification personnel; Grade 10.9 high-strength bolts must be replaced with new bolts once loosened and cannot be reused.
Motor replacement A1/A2/A3: Before disassembly, the arm must be mechanically locked with a lifting device/rope; Disassemble the connector; Disassemble the motor; Apply lubricating grease to the gear meshing surface; Reinstall, torque step by step diagonal tightening; After the repair is completed, the axis origin master calibration must be performed.
Disassembly and assembly of A4-A6 wrist motor and universal drive shaft: distinguish between universal shafts with fastening screws and O-ring versions; Perform A4-A6 origin calibration after disassembly and assembly.
Disassembly and assembly process of input gear units A1/A2/A3.
Electrical wiring instructions: MFH multifunctional housing, RDC box; Complete set of motor, temperature, and encoder wiring diagrams.
Discontinuation, Storage, and Scrap Disposal
Shutdown disassembly process: The robot moves to the transport position, disconnects the cables, and removes the grounding.
Long term storage: take protective measures; Sealed interface.
Scrap: Mechanical components, hydraulic oil, and pressure components should be classified and disposed of according to local regulations.
Options
Release device without drive: manually release the brake and move the robotic arm under power-off conditions; Operation steps and reset requirements.
Appendix
Tightening torque table for all key connecting bolts;
List of consumables: gear oil, various types of lubricating grease models;
Search path for safety data sheet;
List of reference standards: EN ISO10218-1 Mechanical Safety, Pressure Equipment Directive, EN ISO14971, etc.