KUKA Robots KR CYBERTECH-3 Assembly Instructions
KR CYBERTECH-3 body assembly guide, including two models: KR 25 R1840-3, KR 35 R1840-3; Supports installation at any tilt angle for ground, wall, and ceiling, compatible with KR C5 S6/S7 controllers. The manual covers the entire content of the product introduction, safety regulations, technical parameters, project planning, transportation, installation and operation, maintenance, repair, decommissioning, storage and scrapping, options, and appendices.
Product Description
Robot system composition: robotic arm body, KR C5 controller, connecting cables, smartPAD-2 teaching pendant, software, tools and options.
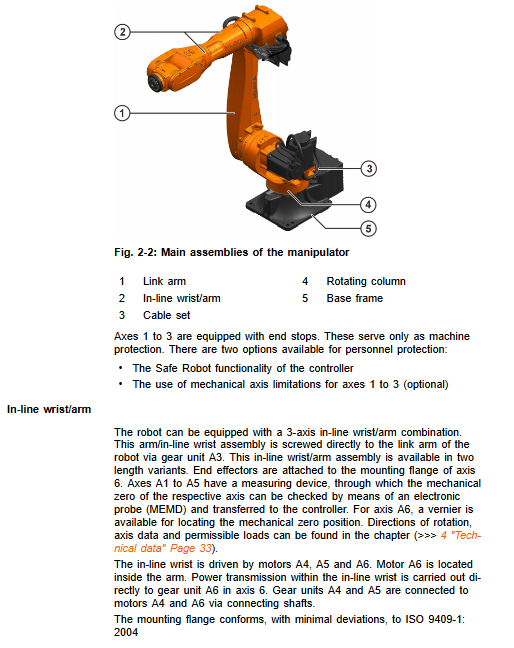
Mechanical arm body structure: 6-axis series articulated robot, assembly: straight wrist inline wrist, linkage arm, rotating column, base frame, complete set of electrical wiring harness.
A1-A3 is equipped with mechanical terminal hard blocks, which only provide equipment protection and cannot protect personnel; Personnel protection relies on the SafeRobot safety function of the controller, or by selecting the A1-A3 adjustable mechanical shaft limit.
Straight wrist: A4-A6 integrated wrist; A6 motor is arranged inside the boom; A4/A5 rely on the drive shaft for transmission; Wrist flange ZH25/ZH35, following ISO 9409-1.
The rear A1 interface of the base integrates RDC unit; All motors and signal cables use Han Yellock quick plug connectors.
Permitted use and prohibited misuse
✅ Allow: handling, assembly, and workpiece handling, strictly adhering to environmental conditions and maintenance cycles.
❌ Prohibited: climbing, carrying people and animals, outdoor activities, explosion-proof areas, radioactive activities, and underground operations; Unauthorized use will result in the loss of warranty.
Robots belong to partially completed machinery and cannot be put into operation independently; The system integrator completes the entire system, issues an EC conformity declaration, and affixes the CE mark.
Available options: Release device for brake release, transport fork slot, lifting ring, A1-A3 mechanical shaft limit, S310 centering base, S260/S310 reinforcement frame.
Technical Data
Basic Overview of Two Models
Parameters KR 25 R1840-3 KR 35 R1840-3
Number of axes: 6 axes, fully controlled. 6 axes, fully controlled
Rated load 25 kg 35 kg
Maximum load 38 kg 49 kg
Maximum reach distance 1840 mm 1840 mm
Repetitive positioning accuracy ISO 9283 ± 0.03 mm ± 0.03 mm
The self weight of the body is about 237 kg
Protection level body IP54, wrist IP67 Body IP54, wrist IP67
Noise<75 dB (A)<75 dB (A)
Installation method: Ground, wall mounted, suspended ceiling, with any inclination angle of ± 180 °. Ground, wall mounted, suspended ceiling, with any inclination angle of ± 180 °
Compatible controllers KR C5 S6/S7 KR C5 S6/S7
Operating temperature range: 0-45 ℃; Storage -25~60 ℃, operation: 0~45 ℃; Storage -25~60 ℃
Axis parameters: Range of motion for each axis of each model, maximum axis speed, Mastering zero position; Tilt installation will limit the range of motion of the A1 axis, and the actual installation tilt angle must be filled in the WorkVisual software, otherwise overload and accidental motion may damage the robot; Attached are a two-dimensional drawing of the work envelope and a limit curve for the variation of the A1 axis with the installation inclination angle.
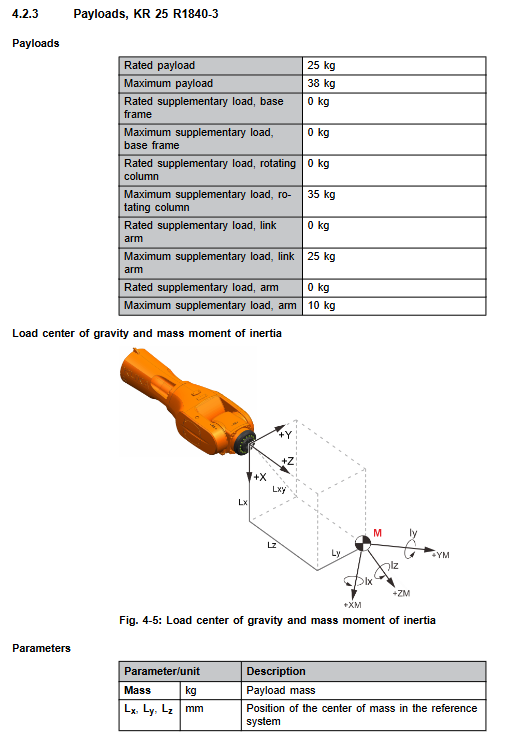
Load chapter: Wrist flange ZH25/ZH35 (ISO 9409-1); Load center of gravity, moment of inertia, load curve diagram; Distinguish between normal operation and emergency stop conditions, flange bearing axial force, radial force, overturning moment, and torsional moment; Provide installation hole drawings and allowable additional load values for the boom, link arm, and rotating column.
Base load: Output vertical force, horizontal force, overturning moment, and A1 torque for ground, ceiling, and wall mounted working conditions respectively; The structural verification must take the maximum value of the emergency stop condition to prevent overturning and falling.
Cable parameters: motor cable XD30, data cable XF31; The cable can be selected in lengths of 2.7-50 meters, with a maximum total length of 50 meters, and can be extended up to once; Specify the minimum dynamic bending radius; Must have independent dual protection grounding; Complete A1 base interface pin diagram and wiring schematic.
Stop distance and stop time: distinguish between STOP0 cutting off the brake and STOP1 safe stop; Provide A1-A3 stop angle and stop time curves for two robots based on different arm extension ratios (33%/66%/100%), program magnification POV, and different loads; The brake will wear out, it is recommended to conduct an annual on-site review of the actual stopping distance; STOP0 has a significant impact on robots and should be triggered as little as possible.
Please refer to KUKA Xpert for information on the location of the body nameplate and REACH regulations.
Planning and Design
Reminder for accelerated wear conditions: long-term temperature limit operation, corrosive dust environment, continuous performance limit, single axis high duty cycle, monotonic reciprocating short stroke, wrist long-term static, external process force; Consult KUKA for the above working conditions to shorten the maintenance cycle; The body comes with overheating and overload monitoring, and automatically shuts down when exceeding the limit.
Two base schemes
Centering option base S310: concrete floor; Concrete grade C20/25; Bottom plate, chemical anchor bolt, positioning pin; Provide basic cross-sectional drawings and prohibit the addition of sound insulation and leveling layers between the base and concrete.
Rack mounted installation: customer steel structure, KUKA linear slide table; 4 M20 bolts+2 locating pins; Strictly follow the drawing requirements for the flatness, roughness, and structural stiffness of the installation surface.
Cable planning: The minimum dynamic bending radius for motor cables is 150 mm, and for data cables it is 60 mm. Power cables and signal cables are laid separately in metal cable trays to ensure EMC electromagnetic compatibility; Double protection grounding; Cable layout eliminates tripping risks; Cables are prohibited from withstanding tensile forces.
A1 Base Interface Definition: Motor X30, Data X31, Mastering Calibration X32, External Shaft XP7.1/XP8.1, I/O Interface X76 Drawing.
Transportation
Forced transportation posture (must be maintained throughout the entire process, and the posture must not be changed before being fixed to the base to prevent tipping)
A1=0°,A2=‑130°,A3=168°,A4=0°,A5=0°,A6=0°
Shipping Method
Forklift: Optional fork slots must be installed;
Crane: using M12 lifting rings, with lifting points distributed around rotating columns and base frames;
Prohibit lifting from non-standard lifting points; Avoid impact and vibration; Dismantle the lifting ring/fork groove in place; Provide the overall dimensions and center of gravity position drawings for the transportation of the entire machine.
Startup Debugging and Restarting
Distinguish between two installation forms: floor mounted with fixed base and rack mounted (floor/wall/ceiling) installation.
Prerequisite: The robot is in a transport position, the base steel structure is completed, and the lifting equipment is in place.
General installation steps
Lift into place and install the positioning pin;
M20 bolts are tightened diagonally in multiple stages to the specified torque;
Connect double protection grounding (torque 15 Nm);
Connect motor cable XD30 and data cable XF31; The clicking sound of the connector indicates locking, and the lock buckle can rotate 90 degrees to prevent accidental unlocking;
Fill in the actual installation posture and inclination angle of the robot using WorkVisual software;
Install tools, power on, jog in T1 mode, perform axis Mastering zero calibration, and perform overall functional testing.
After 100 hours of operation, all anchor bolt torques must be rechecked.
Provide a complete schematic diagram of the wiring of KR-C5-S motor cables, data cables, and grounding cable pins.
Maintenance
Only allow maintenance projects recorded in the manual to be executed; The remaining repairs will be entrusted to KUKA authorized personnel; Emergency stop, lock and power off before maintenance; The maintenance cycle is shortened when the operating oil temperature exceeds 60 ℃; This series of robots does not have a hydraulic nitrogen balance cylinder.
Maintenance Cycle Summary Table (KR 25 R1840-3/KR 35 R1840-3)
Periodic homework content consumables
10 000 h A1 cable package coated with Optitemp RB2 grease 0.08 kg
10 000 h A4 cable package coated with Optitemp RB2 grease 0.06 kg
20 000 h or at the latest 5 years, replace all gearboxes with Optigear Synt. ALR 150 gear oil; Drei Bond 5204HV sealant
Suggest KUKA to conduct a comprehensive on-site inspection of the entire machine after 7 years or changes in operating conditions.
Key maintenance process
A1/A4 cable package lubrication: Remove the base cover plate, visually inspect the corrugated tube, apply lubricating grease with a brush, restore the cover plate, and jog the corresponding axis to evenly distribute the grease.
General rules for gearbox oil change: The gearbox is at operating temperature; Measure the actual amount of oil released during oil discharge; The gearbox must be flushed if the oil release rate is less than 70% of the rated value; Rinse twice with less than 50%, and move the entire stroke during rinsing; Magnetic plug inspection for metal debris; Tighten the plug according to the specified torque; Oil change completed T1 mode jog operation, check for leaks.
Initial oil filling amount for each gearbox: A1=1.70 L; A2=1.10 L; A3=0.40 L; A4=0.20 L; A5=0.15 L.
Robot cleaning: Prohibit high-pressure water guns and direct blowing of compressed air on bearing seals; Use water-soluble neutral cleaning agents; Power off operation to prevent liquid from entering the electrical chamber.
Maintenance
This manual only explains the prerequisites and safety regulations for maintenance operations. Specific disassembly and assembly work for motors, wrists, etc. must be completed by KUKA authorized personnel.
General safety maintenance: Power off, lock the main switch, wait for 5 minutes for high-voltage discharge; Before disassembling the motor, the corresponding shaft must be mechanically locked to prevent the arm from accidentally falling;
Repairs must use KUKA original spare parts; Complete verification of all safety functions after maintenance is completed.
Suspension, Storage, and Disposal
Shutdown disassembly: The robot moves to the designated transport posture; Install lifting rings and slings; Disconnect all cables; Lift the crane off the main body.
Storage: Maintain transportation posture, clean the robot, and do a good job of rust prevention and protection; The storage environment should be dry, dust-proof, avoid condensation, and meet the storage conditions of temperature and humidity; Electrical interface sealing protection.
Scrap disposal: Classified by material (cast steel, cast aluminum, copper cable, electronic components, various plastics, lubricants, sealants), and disposed of according to local environmental regulations.
Options
Release device: manual movement of the robotic arm in power-off state; Provide a complete explanation of the installation process and safety constraints for a non actuated mobile robotic arm.
S310 centering base, S260/S310 reinforced frame, fork slot transport component, lifting ring, A1-A3 mechanical shaft limit.